Home | Contents | 日本語
CHAPTER 8
Applications to Biomechanics and Impact
Biomechanics
The force controllability of human fingers and the impact responses of the arm and palm were evaluated with the LMM.
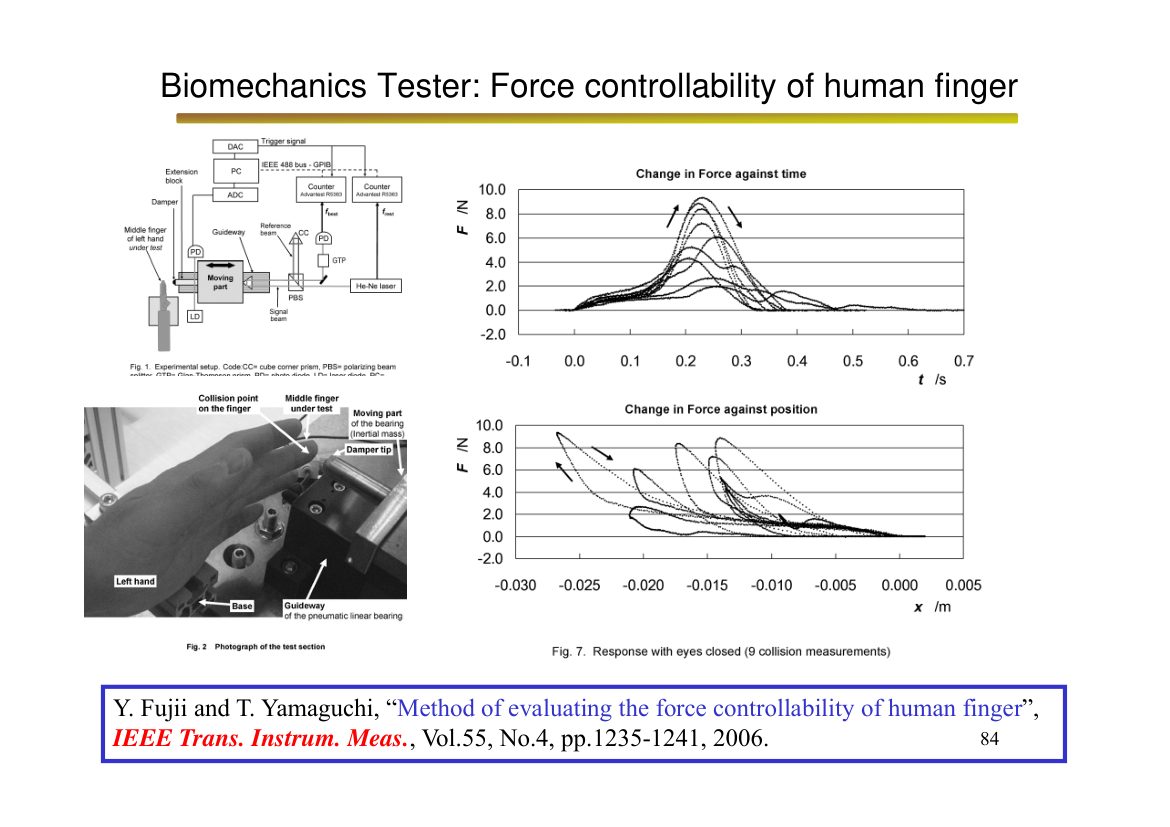
Figure: Evaluating the force controllability of the human finger (IEEE Trans. Instrum. Meas., 2006)
- Y. Fujii, T. Yamaguchi, "Method of evaluating the force controllability of human finger", IEEE Trans. Instrum. Meas., Vol.55, No.4, pp.1235–1241, 2006.
- Y. Fujii, T. Yamaguchi, J. Valera, "Impact response measurement of a human arm", Exp. Tech., Vol.30, No.3, pp.64–68, 2006.
- H. Ito, Y. Fujii, "Evaluation of mechanical response of human palm to small impact force", Electron. Commun. Jpn., Vol.92, No.1, pp.18–23, 2009.
Impact
Impact responses of a bamboo sword and of an accelerometer, and the impact force on a ball dropping onto a water surface, were measured.
- Y. Fujii, "Impact response measurement of an accelerometer", Mech. Syst. Signal Process., Vol.21, No.5, pp.2072–2079, 2007.
- R. Araki, A. Takita, T. Ishima, H. Kawashima, N. Pornsuwancharoen, S. Punthawanunt, E. Carcasona, Y. Fujii, "Impact force measurement of a spherical body dropping onto a water surface", Rev. Sci. Instrum., Vol.85, 075108, 2014.
Actuators
The force generated by a voice-coil linear motor is measured as the inertial force of the levitated mass, to evaluate its electrical and mechanical characteristics in motion. Force was almost proportional to current, with high reproducibility over eight periods of reciprocating motion.
← Previous: 7. Material Testing and Micro-Force | Next: 9. Measurement Techniques →
Contents
The Levitation Mass Method: precision force measurement by the definition of force | Yusaku Fujii (Gunma University)